robotic-manipulation
(3)
Dyna Robotics
Dyna Robotics is a Redwood City, California startup building embodied-AI foundation models that let robots perform dexterous, real-world manipulation tasks around the clock. Founded in 2024 by repeat entrepreneurs Lindon Gao and York Yang (who sold Caper AI for $350M) and former DeepMind researcher Jason Ma, the company's DYNA-1 model runs commercial deployments in laundries, factories, restaurants and gyms. Dyna raised a $23.5M seed and a $120M Series A in 2025, reaching a valuation above $600M with backing from NVIDIA, Amazon, Salesforce Ventures, Samsung Next and CRV.
Tacta Systems, Inc.
Tacta Systems is a Palo Alto robotics startup building 'Dextrous Intelligence' - a smart nervous system that combines proprietary software, hardware and AI to give robots human-level tactile skills and spatial awareness. Founded by serial hard-tech entrepreneur Andreas Bibl (whose previous company LuxVue was acquired by Apple), Tacta aims to let robots sense, adapt and manipulate the physical world with human-like precision and speed, automating factory work and grueling physical labor. The company emerged in 2025 with $75 million in seed and Series A funding.
Pickle Robot Company
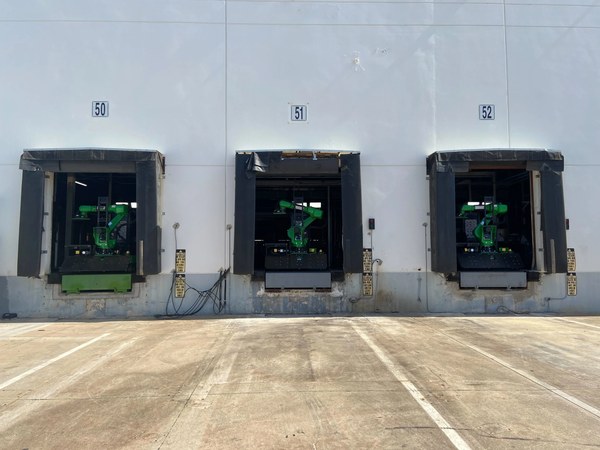
Pickle Robot Company builds Physical AI systems that autonomously unload trucks, trailers, and import containers of non-palletized goods at human-scale or better. Founded in 2018 and based in Cambridge, Massachusetts, Pickle pairs a multi-camera vision system with generative AI foundation models trained on millions of real warehouse data points, mounting a KUKA arm on a custom mobile base that drives into a trailer and clears it in roughly 90 minutes. The company is on a mission to automate inbound and outbound work at one million warehouse doors over the next decade.